<- back to thoughts
Going 3D: bots that never let go
Log #3. Linked bots on a 3D grid, and a real bot to aim for.
october 2026 • robotics, programmable matter, simulation • 1 min read
project logMicrobots: programmable matteron /projectsentry 4 of 7
- 1Programmable Matteroctober 2026
- 2Dots and a flockoctober 2026
- 3Bots that build a shapeoctober 2026
- 4Going 3D: bots that never let goyou're here
- 51,000 bots in the browseroctober 2026
- 6From hand-written rules to a trained modeloctober 2026
- 7Making it local, and catching broken botsoctober 2026
The Kilobots just stopped next to each other on a table. Real programmable matter has to hold itself up, so every bot has to stay linked to the structure the whole time the swarm is reshaping.
A real bot to aim for
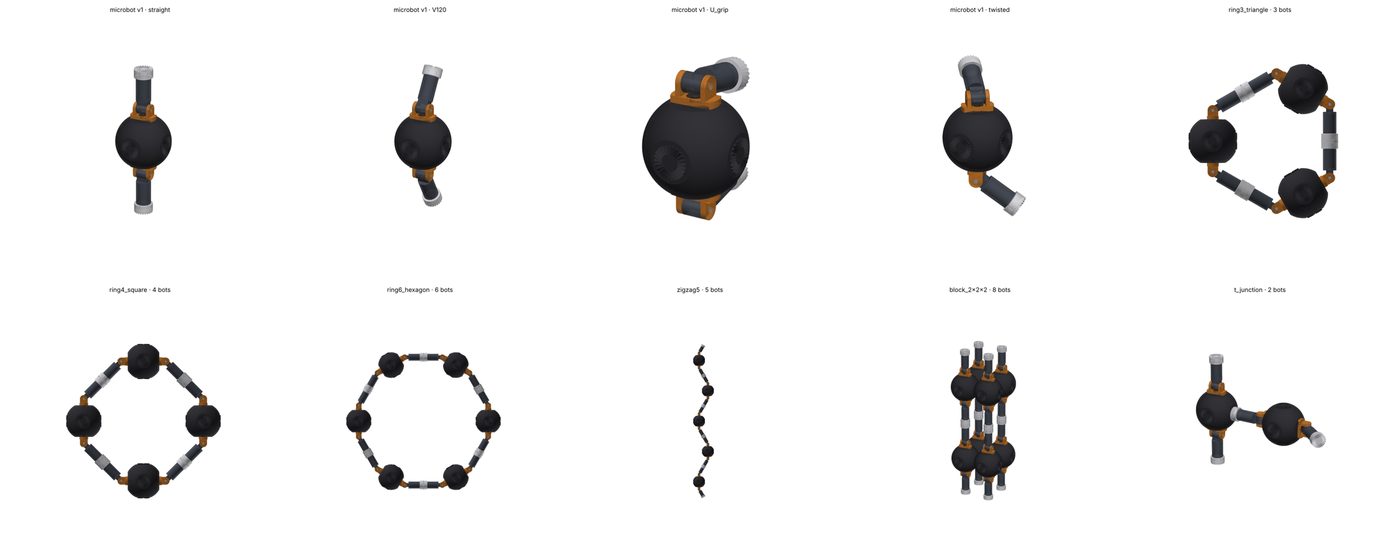
Kuan designed microbot v1 in CAD: a ball with two 3-joint arms and side ports, so the arm tip of one bot docks into the side of the next. The bottom row shows them linked into a triangle, a square, a hexagon, a zigzag, a 2×2×2 block and a T-junction. That design sets the rules the simulation has to respect.
The model
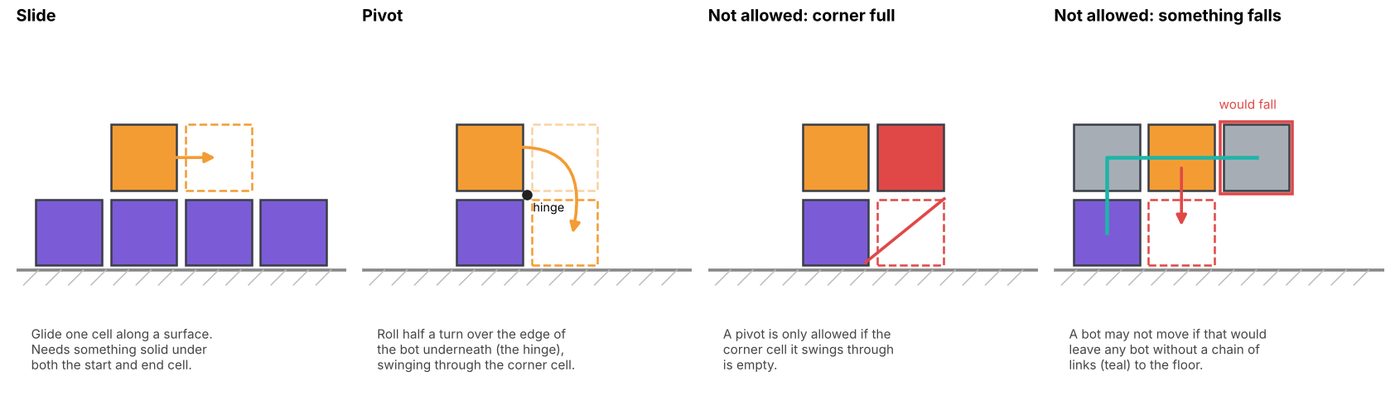
- Bots are cubes on a 3D grid, and bots sharing a face are linked.
- Two moves: slide along a surface, or pivot (flip over the edge of the bot underneath).
- Two rules: a pivot needs the corner it swings through to be empty, and no move may leave any bot without a chain of links to the floor. Nothing ever falls.
Bots crawl over the outside of the structure towards the empty cells of the shape and lock in when they arrive. Then I cut the middle out of the arch's bridge. Each half stays up on its own, sticking out over nothing, because every bot is still linked back to its leg. The spares climb back up and rebuild it.
What didn't work at first: bots trying to climb through empty air built ladders to nowhere; paths that only allowed straight steps couldn't reach the top of a wall one bot thick; and with no floor counted as an anchor, one cut dropped a whole leg. Each fix is in the experiment log.