<- back to thoughts
1,000 bots in the browser
Log #4. A 3D sandbox, harder shapes, Kuan's bot, and support pillars.
october 2026 • robotics, three.js, simulation • 2 min read
project logMicrobots: programmable matteron /projectsentry 5 of 7
- 1Programmable Matteroctober 2026
- 2Dots and a flockoctober 2026
- 3Bots that build a shapeoctober 2026
- 4Going 3D: bots that never let gooctober 2026
- 51,000 bots in the browseryou're here
- 6From hand-written rules to a trained modeloctober 2026
- 7Making it local, and catching broken botsoctober 2026
I ported the linking rules to a single web page with a 3D view, so anyone can open it, spin it around and knock holes in it.
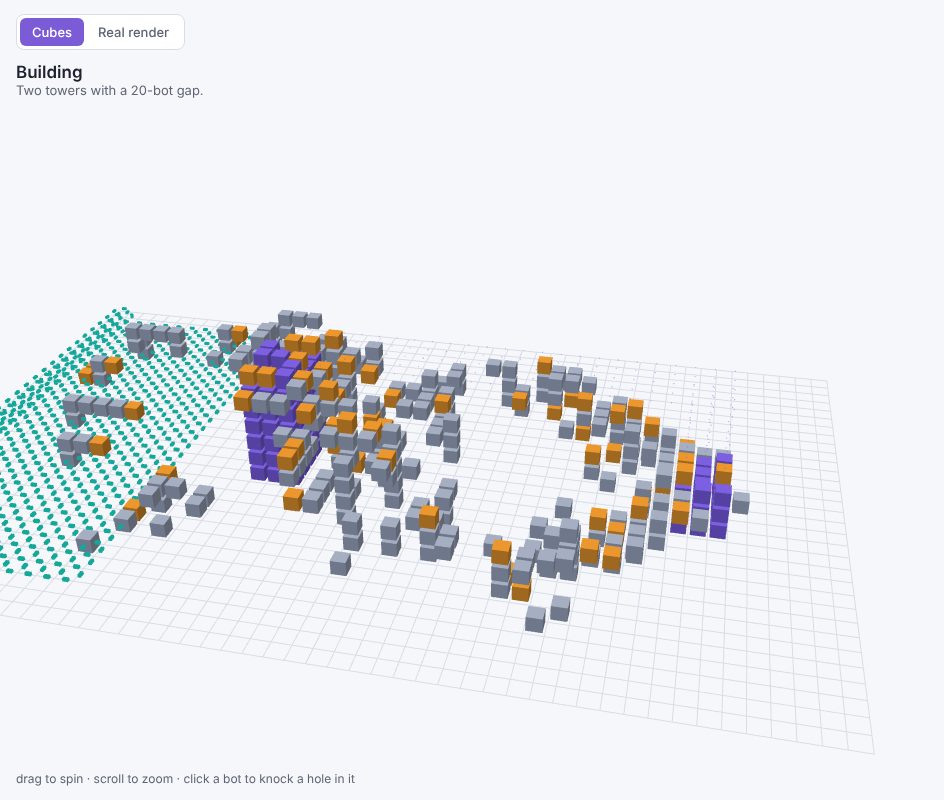
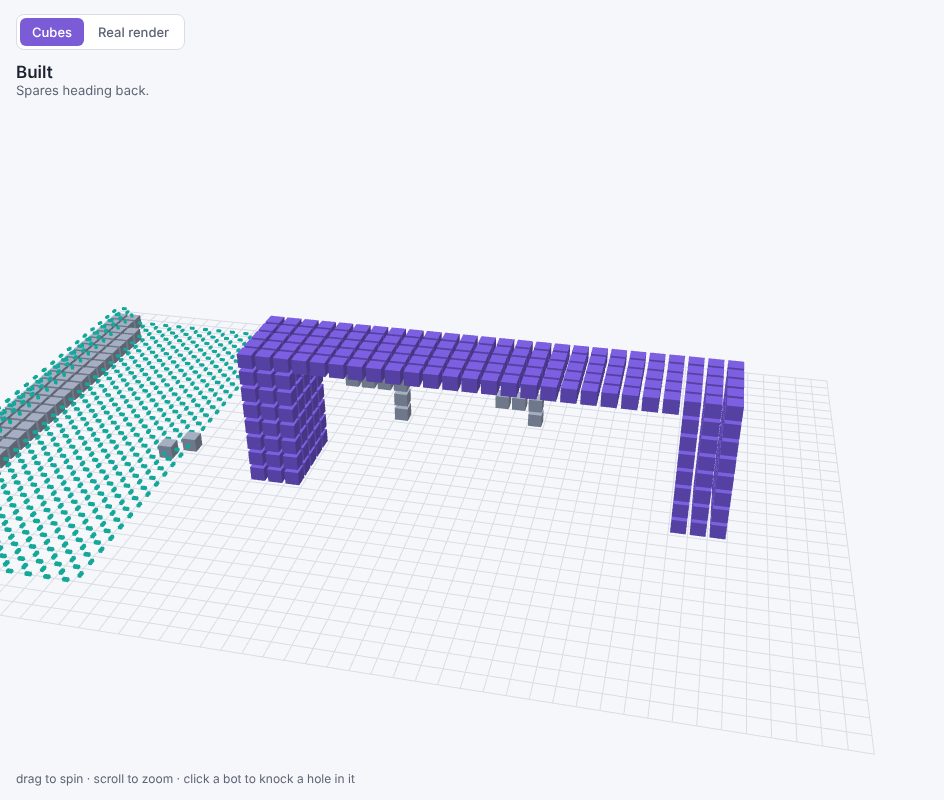
Grey bots are free, purple ones are locked into the shape, orange ones are mid-flip, and the teal pad is where spares park. Click a bot and it knocks a hole out of the structure; the swarm fixes it.
Harder shapes, new problems
Scaling to ~1,000 bots and harder shapes (dome, spiral staircase, pyramid, the letter K, a table) broke things in interesting ways:
- One big blob. With two separate build sites, everyone headed for the nearest one, so the whole swarm moved as one mass. Fixed by sharing bots out by how much work each site has left.
- Sealed in. Bots crawled inside the dome to help, and it closed over them. Fixed by keeping bots out of space the finished shape will enclose.
- Boxed-in holes. Bots crowded around a hole none of them could reach. Fixed by having one bot claim each hole while the others give way.
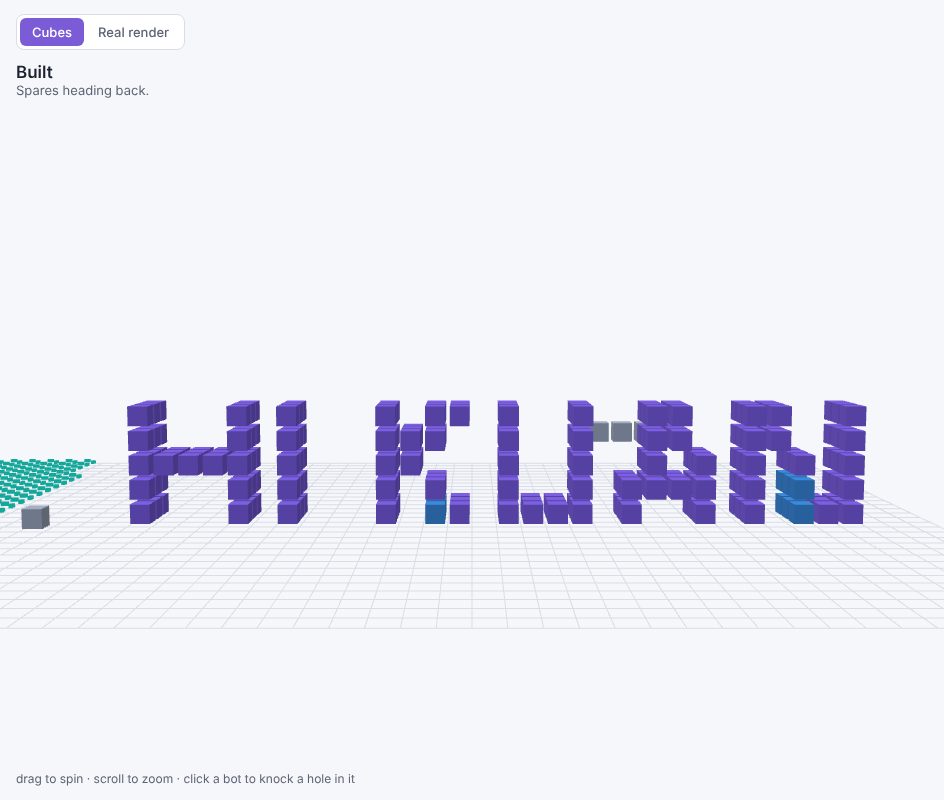
You can also type something and it gets built as 3D letters.
Kuan's bot in the sandbox
The "Real render" view draws every bot as microbot v1 and switches to its linking rules: a link is one bot's arm tip plugged into a side port of its neighbour, so bots that only touch aren't attached. Bots pick an arm direction that points at something real, preferring vertical, and that alone made pillars alternate between bots holding vertically and bots held sideways.
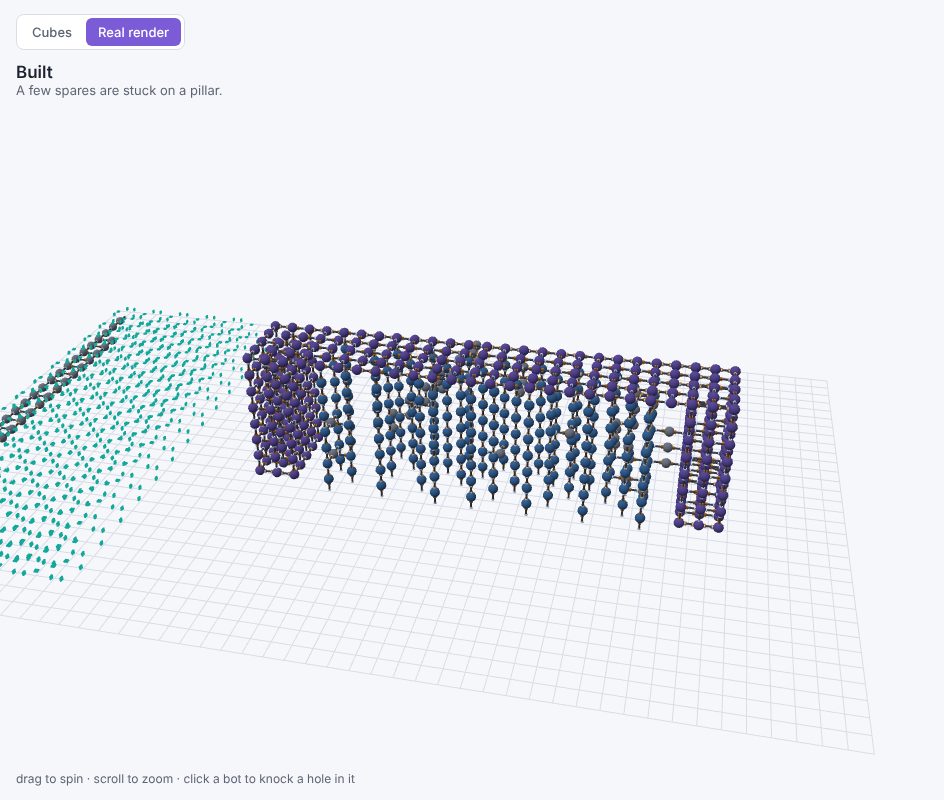
With real connector strength on, only one bot can stick out sideways before a connector would peel (about 3 N per connector, still to be measured). Before I added any planning, spare bots sometimes piled up under the deck and held it up like scaffolding, which nobody told them to do. It didn't happen every run, so now the swarm plans support pillars (blue) and builds them first.
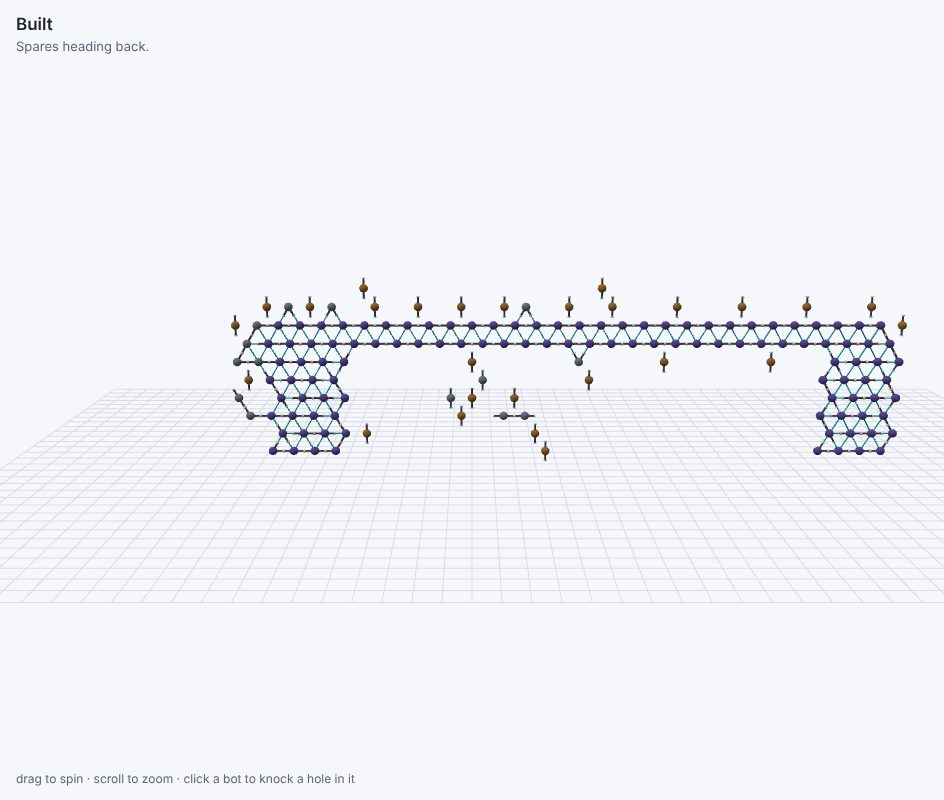
v1's links naturally make triangles and hexagons, so the bridge can also be built as a truss on a triangle grid, with bots rolling 60° around a shared neighbour.